
The Engineering Reality of Motor-Drive Matching
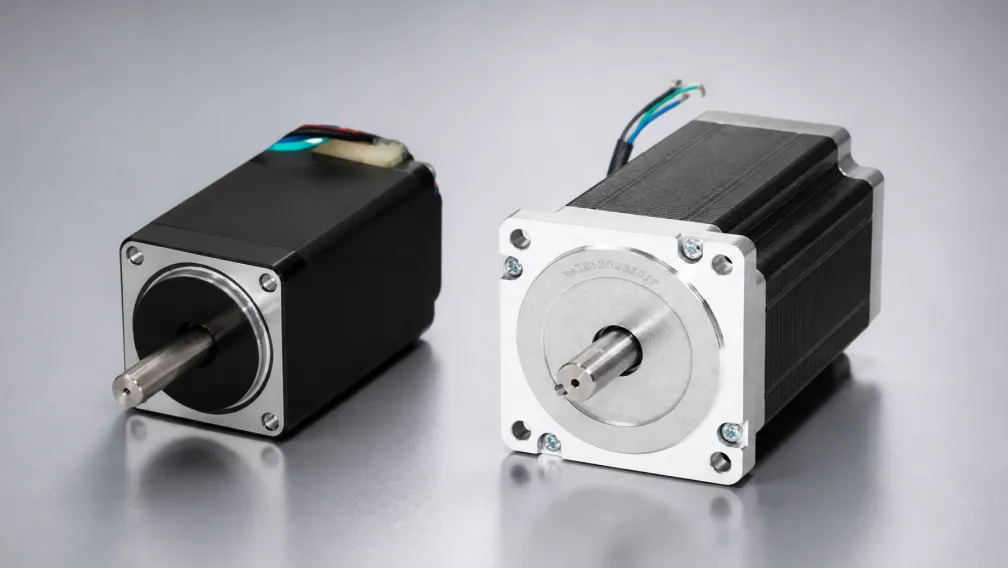
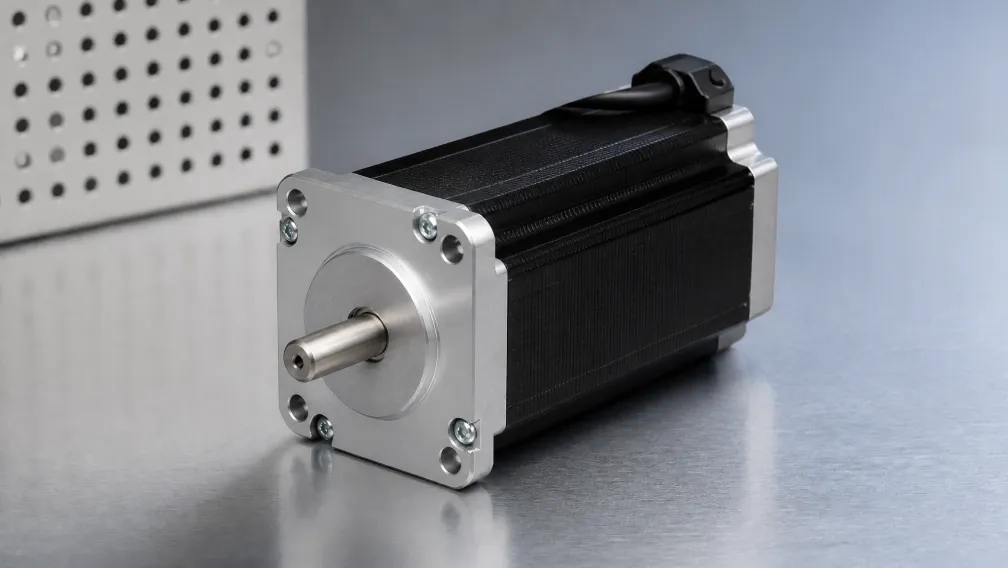
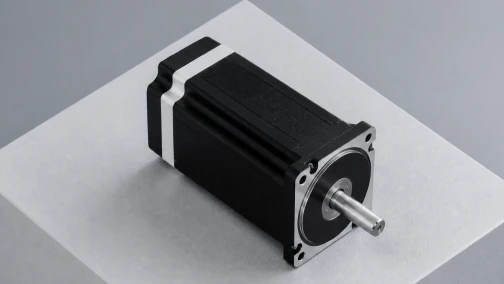
In industrial motion control, specifying a high-torque stepper motor solves only half of the mechanical equation. The motor is merely a passive electromagnetic actuator; its dynamic performance is entirely dictated by the power regulation capabilities of the attached motor driver. A mismatched driver-motor pair results in severe operational bottlenecks: insufficient bus voltage caps high-speed torque, incorrect current configurations cause thermal overload, and mismatched optocoupler bandwidths lead to dropped pulses at high microstep resolutions.
Engineers often rely on basic voltage and current ratings printed on the motor datasheet, a practice that frequently leads to suboptimal system integration. The "rated voltage" of a stepper motor is an obsolete metric derived from Ohm's Law (V = I * R) for steady-state DC holding conditions. In actual dynamic operation, a modern bipolar chopper drive applies voltages 10 to 20 times higher than this static rating to overcome inductive reactance. This technical guide outlines the electrical calculus required to match a stepper motor to a bipolar chopper drive, focusing on inductance limits, RMS versus peak current scaling, regeneration management, and signal bandwidth.
1. The Calculus of Inductance and Bus Voltage Limits
When a stepper motor rotates, the internal magnetic fields generate a Back-Electromotive Force (Back-EMF) that opposes the supply voltage. Furthermore, the stator windings possess electrical inductance (measured in millihenries, mH), which physically resists the rapid changes in current required to execute a step. As rotational velocity increases, the step commutation window narrows. If the driver's supply voltage is too low, it cannot force the current to its target level before the next step occurs, causing dynamic torque to plummet.
To calculate the optimal maximum bus voltage for a specific motor based on its inductance, engineers use the established empirical formula:
V_optimal = 32 * sqrt(L)
Where V_optimal is the maximum direct current (DC) supply voltage, and L is the phase inductance in millihenries (mH). For example, a NEMA 34 motor with a phase inductance of 6.5 mH yields an optimal voltage of 32 * sqrt(6.5) = 81.6 VDC. If an engineer pairs this motor with a driver limited to 24 VDC, the motor will operate safely at standstill but will experience torque starvation and stall at relatively low RPMs. Conversely, exceeding the V_optimal threshold risks exceeding the insulation breakdown voltage of the stator windings or inducing severe low-speed resonance.
2. Peak vs. RMS Current: Deciphering the Ratings
Configuring the output current on a stepper driver is the most frequent source of commissioning errors. Motor manufacturers typically rate phase current in Amps RMS (Root Mean Square), representing the continuous thermal limit of the copper windings. However, driver manufacturers often label their DIP switches or software settings in Amps Peak.
Because a microstepping driver synthesizes a sinusoidal current waveform, the relationship between Peak and RMS is governed by the crest factor of a sine wave:
I_peak = I_rms * 1.414
If a motor datasheet specifies a rated current of 3.0A (RMS), configuring the driver to output 3.0A Peak means the motor is only receiving 2.12A RMS. This underpowering reduces available torque by approximately 30%. To match the motor's true thermal rating, the driver must be set to 4.2A Peak (3.0 * 1.414). Engineers must carefully verify whether the drive's documentation references Peak or RMS values before finalizing the parameter limits. Overdriving a motor beyond its RMS rating will rapidly exceed its Class B (130°C) or Class F (155°C) thermal insulation limits.
3. Bipolar Chopper Topology and di/dt Management
Modern stepper drives utilize a bipolar chopper topology (Pulse Width Modulation, or PWM) to regulate current. Rather than supplying a constant voltage, the drive connects the full power supply voltage across the winding to rapidly build current (di/dt = V/L). Once the current reaches the target threshold set by the internal comparator, the drive shuts off the transistor, allowing the current to recirculate and decay.
Matching the drive's PWM frequency and decay mode to the motor's inductance is critical. Low-inductance motors require high-frequency PWM switching (typically 40 kHz or higher) to prevent excessive current ripple. If a low-inductance motor is paired with a legacy drive operating at a 20 kHz chopper frequency, the current will overshoot the target threshold during each PWM cycle, resulting in massive heat generation and audible acoustic whine. Modern DSP-based drivers automatically calculate the internal PI (Proportional-Integral) loop gains to match the specific L/R time constant of the connected motor, effectively automating this calculus.
4. Optocoupler Bandwidth and Microstep Frequencies
The interface between the machine controller (PLC or CNC board) and the stepper driver relies on opto-isolated signal inputs to protect the low-voltage logic from electrical noise. These optocouplers have strict frequency bandwidth limits, commonly ranging from 100 kHz to 500 kHz.
Engineers must calculate the required pulse frequency to ensure it does not exceed the driver's input bandwidth. The required frequency is determined by the target maximum RPM and the configured microstep resolution:
Pulse Frequency (Hz) = (Target RPM / 60) * (200 * Microstep Multiplier)
If an axis requires 1,200 RPM and the drive is set to 32 microsteps (6,400 pulses per revolution), the controller must output:
(1200 / 60) * 6400 = 128,000 Hz (128 kHz)
If the selected driver utilizes lower-tier optocouplers with a 100 kHz limit, the drive will fail to register a portion of the pulses, resulting in severe positional deviation and axis drift. When specifying a drive for high-speed, high-resolution applications, verifying the maximum input pulse frequency (typically 200 kHz for industrial standard drives) is a non-negotiable engineering requirement.
5. Power Supply Selection and Regeneration Handling
The power supply acts as the foundation of the motor-drive ecosystem. Switched-Mode Power Supplies (SMPS) are the industry standard due to their low weight and high efficiency. However, a stepper motor decelerating a high-inertia load operates as an electrical generator, dumping kinetic energy back into the driver as regenerated voltage.
An SMPS cannot absorb back-EMF. If the regenerated energy forces the bus voltage above the driver's Over-Voltage Protection (OVP) threshold, the drive will fault and disable the axis to protect its MOSFETs. To match a drive and power supply to a high-inertia load, engineers must employ one of three strategies:
- Specify a driver with an integrated braking resistor circuit that bleeds off excess voltage as heat.
- Use an SMPS equipped with a built-in regeneration clamp.
- Select a driver with a maximum voltage rating significantly higher than the power supply (e.g., using a 48V power supply on a driver rated for 80V), providing a wide voltage buffer to absorb transient back-EMF spikes.
6. The Engineering Solution for Guaranteed Integration
Question: How do automation engineers guarantee that a selected drive will maximize the torque-speed curve of a specific motor without triggering thermal or over-voltage faults?
Answer: Engineers execute a three-point verification: First, they apply the V = 32 * sqrt(L) formula to select a bus voltage that overcomes the motor's specific phase inductance. Second, they verify the driver's maximum current output accommodates the motor's Peak current requirement (RMS * 1.414). Finally, they confirm the drive's input optocoupler bandwidth exceeds the maximum frequency generated by the controller's required RPM and microstep configuration. If these three electrical boundaries are aligned, the motor-drive pair is mathematically validated.
7. Upgrading to Closed-Loop Drive Architectures
While matching open-loop components requires strict adherence to inductance and current limits, engineers frequently migrate to closed-loop stepper motors for demanding applications. A closed-loop drive (often called a hybrid servo) relies on high-resolution encoder feedback to actively manage current. Instead of blindly pushing the peak rated current into the motor at all times, the drive calculates the exact load requirement via Field-Oriented Control (FOC) and supplies only the necessary current vector.
This active matching eliminates the risk of resonance, drastically reduces thermal dissipation, and effectively operates as an AC servo system at a fraction of the cost, bypassing the rigid static configurations required in traditional open-loop drive matching.
Frequently Asked Questions (FAQ)
Question: Why is my stepper motor rated for 3.6V, but the driver requires a 24V or 48V power supply?
Answer: The 3.6V rating is a static DC measurement based on the internal winding resistance (Ohm's Law). In a dynamic running state, the motor's inductance strongly resists the flow of current. The driver requires a much higher bus voltage (like 24V or 48V) to punch through this inductive reactance quickly, allowing the magnetic field to build fast enough to maintain torque at higher RPMs.
Question: What happens if I set the driver's current output higher than the motor's rated RMS current?
Answer: The motor will generate excessive waste heat (I²R losses). If the internal temperature exceeds the insulation rating of the copper windings (typically 130°C to 155°C), the insulation will melt, causing internal short circuits and permanent motor failure. Always limit the drive's continuous RMS output to the motor's specified rating.
Question: How do I know if I should set my stepper driver to Peak or RMS current?
Answer: You must consult the driver's hardware manual. Many drives use DIP switches labeled in Peak Amps. If your motor is rated at 4.0A RMS, you must multiply this by 1.414 to find the Peak equivalent (5.65A Peak). Setting a Peak-labeled drive to 4.0A means you are severely underpowering your 4.0A RMS motor.
Question: Can I run multiple stepper motors off a single stepper motor driver?
Answer: In industrial CNC and automation, this is strictly prohibited. A bipolar chopper drive monitors the current loop of a single phase. Connecting multiple motors in parallel alters the total inductance and resistance unpredictably, destroying the drive's ability to regulate the PWM chopper circuit, which leads to erratic movement, stalling, and likely damage to the drive's output transistors.
Question: Why does my motor stall when I increase the microstepping from 16 to 128?
Answer: You have likely exceeded the frequency bandwidth of either your controller or the driver's optocoupler inputs. At 128 microsteps, the required pulse rate is extremely high. If the pulse frequency exceeds the hardware limit (e.g., 100 kHz), the driver will drop pulses, causing the motor to instantly lose synchronization with the command signal and stall.
Question: What is the advantage of using a DSP-based digital stepper driver over older analog drivers?
Answer: DSP (Digital Signal Processing) drivers analyze the motor's electrical characteristics upon power-up. They automatically tune their internal Proportional-Integral (PI) current loops to match the exact inductance and resistance of the connected motor. This eliminates the manual tuning required on older analog drives and drastically reduces mid-band resonance and current ripple.
-

Cymotorix
Stepper Motor & Servo Motor Manufacture
Cymotorix is a China-based motor manufacturer with 20+ years of experience producing hybrid stepper motors, AC servo motors, and matched drivers for OEM customers worldwide.